Hand-controlled vehicle interaction
Developed the tracked-hand road interaction that guides the car. Implemented road detection, attachment and detachment states, bounded steering input, controller selection, and haptic response.
A VR endless-driving prototype where the position of the player’s hand guides a car across a procedurally assembled road.
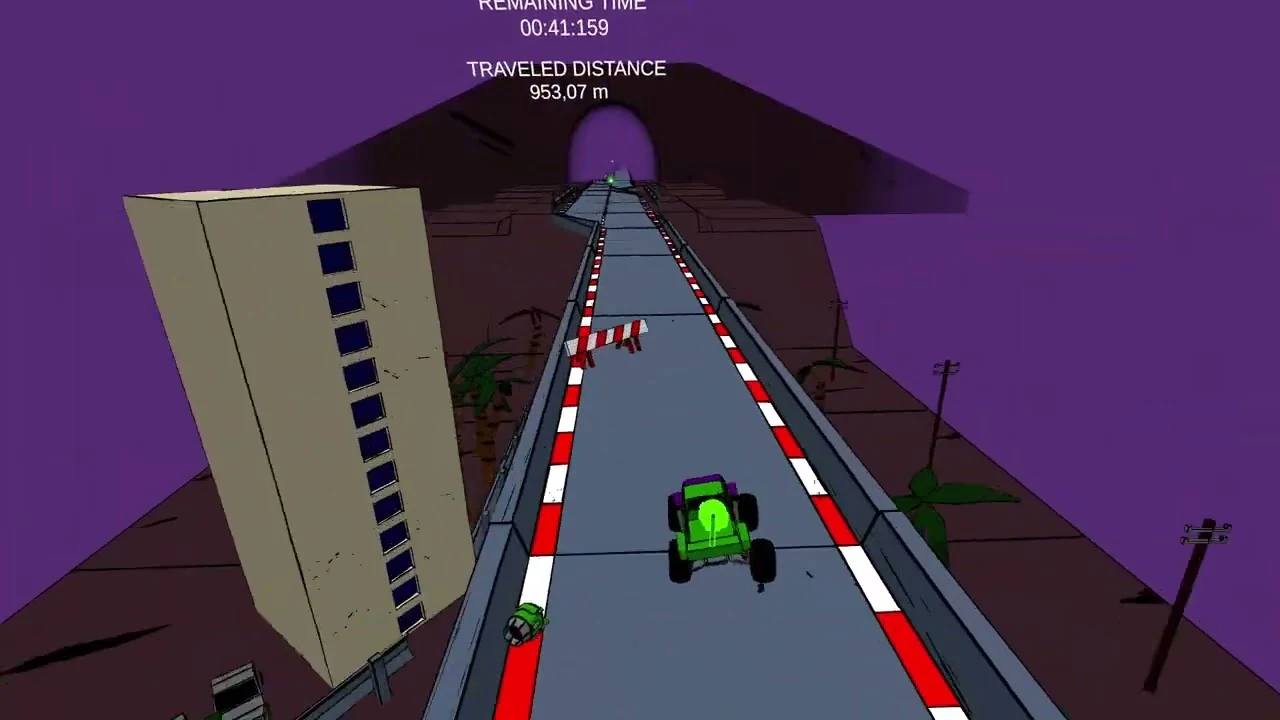
CarIsHand Prototype is an internal Gamedust game-jam experiment: an endless driving game in which the player guides a small car by moving their hand over the road.
I developed the Unity prototype from June to August 2021 alongside a 3D artist. My work covered the core hand-controlled driving interaction, the endless road and obstacle loop, timed gameplay, and the audiovisual feedback that makes the vehicle feel connected to the player.
The supplied gameplay recording is the project’s only public visual. It shows the hand-guided car, the moving road, obstacles, timer, and distance readout in play.
The interaction starts from a tracked hand transform and a road-proximity check. When the active hand is over the road, its position updates the car’s target track position; the vehicle smooths toward that target, turns its wheels, and reacts when the hand leaves the surface. I also connected controller selection and haptic pulses to the interaction state.
The course is assembled from reusable road chunks. The runtime moves active chunks past the player, returns old sections to pools, and chooses weighted replacement chunks while respecting vertical road limits. Configurable props and obstacle variants keep repeated sections from looking identical.
The game loop combines a countdown, travelled distance, time-extending collectables, obstacle penalties, and feedback. I connected vehicle state and gameplay events to FMOD parameters, collision and attachment effects, and particle feedback.
Tools and disciplines behind the project.
Developed the tracked-hand road interaction that guides the car. Implemented road detection, attachment and detachment states, bounded steering input, controller selection, and haptic response.
Built the car-control behavior that follows the tracked target, updates steering and wheel presentation, adapts movement to road speed, and responds to collision and loss of road contact.
Created the reusable road-chunk flow: weighted selection, snap-based placement, elevation constraints, despawning, pooling, and randomized props and obstacle variants.
Implemented the timed run, distance tracking, time collectables, obstacle penalties, start and reset flow, and the connection between game state and player-facing timer feedback.
Integrated FMOD-driven vehicle and gameplay feedback, including speed-linked parameters, engine and collision sounds, attachment effects, particles, and controller haptics.